Alignment: Specifications (page 5 of 5)
- Make
- Mercury
- Model
- Milan FWD
- Engine
- L4-2.3L VIN Z
- Year
- 2007
- Section
- Alignment
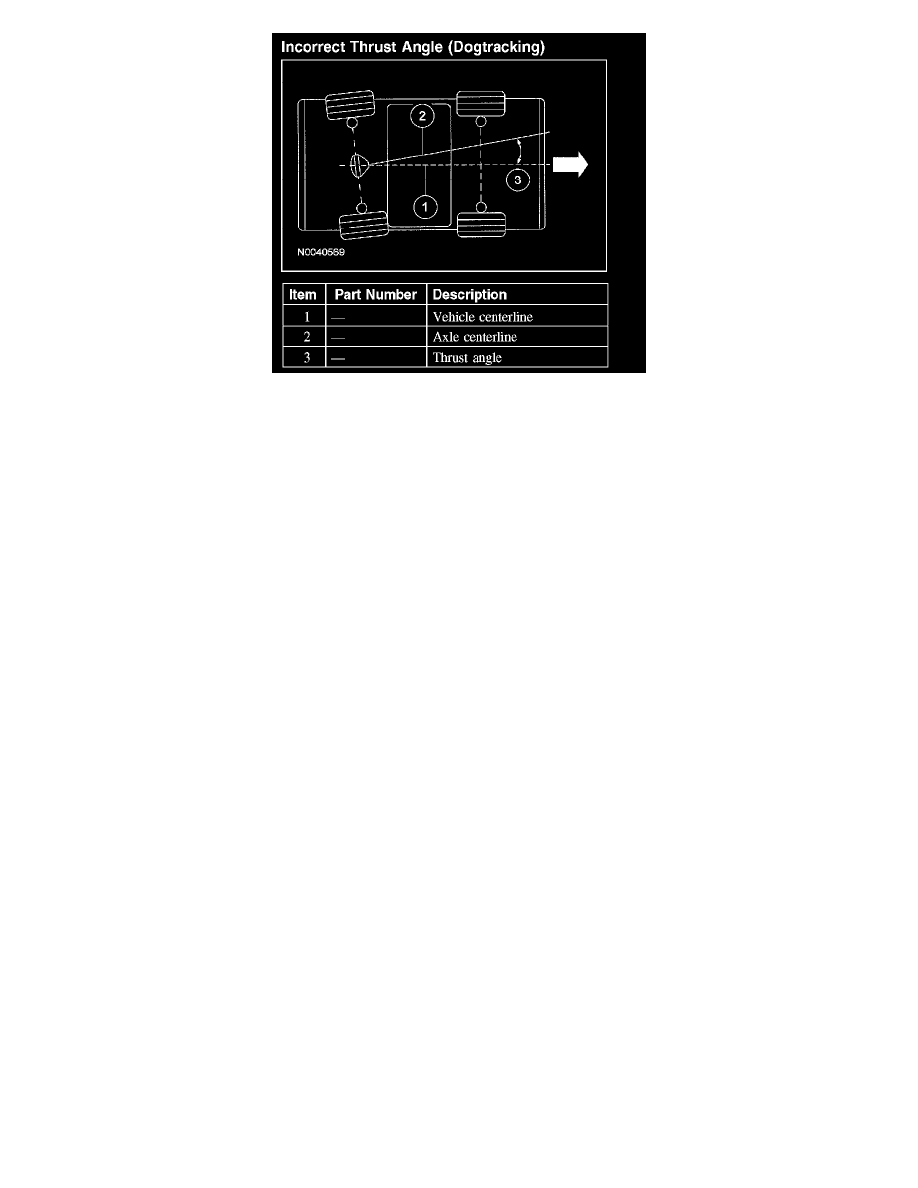
Incorrect Thrust Angle (Dogtracking)
Incorrect thrust angle (dogtracking) is the condition in which the rear axle is not square to the chassis. Heavily crowned roads can give the illusion of
dogtracking.
Wander
Wander is the tendency of the vehicle to require frequent, random left and right steering wheel corrections to maintain a straight path down a level
road.
Shimmy
Shimmy, as observed by the driver, is large, consistent, rotational oscillations of the steering wheel resulting from large, side-to-side (lateral)
tire/wheel movements.
Shimmy is usually experienced near 64 km/h (40 mph), and can begin or be amplified when the tire contacts pot holes or irregularities in the road
surface.
Nibble
Sometimes confused with shimmy, nibble is a condition resulting from tire interaction with various road surfaces and observed by the driver as small
rotational oscillations of the steering wheel.
Poor Returnability/Sticky Steering
Poor returnability and sticky steering is used to describe poor return of the steering wheel to center after a turn or steering correction.
Drift/Pull
Pull is a tugging sensation, felt by the hands on the steering wheel, that must be overcome to keep the vehicle going straight.
Drift describes what a vehicle with this condition does with hands off the steering wheel.
-
A vehicle-related drift/pull, on a flat road, will cause a consistent deviation from the straight-ahead path and require constant steering input in the
opposite direction to counteract the effect.
-
Drift/pull may be induced by conditions external to the vehicle (for example, wind, road crown).
-
A drift or pull condition may exist even if the front alignment is within specifications. To aid in correcting this condition, there are 4 additional
upper control arms available with off-set bushings (2 for LH, 2 for RH). These upper control arms will allow the caster to be adjusted ±0.4
degrees. Refer to Caster Adjustment - Front.
Poor Groove Feel
Poor groove feel is characterized by little or no buildup of turning effort felt in the steering wheel as the wheel is rocked slowly left and right within
very small turns around center or straight-ahead (under 20 degrees of steering wheel turn). Efforts may be said to be "flat on center."
-
Under 20 degrees of turn, most of the turning effort that builds up comes from the mesh of gear teeth in the steering gear. In this range, the
steering wheel is not yet turned enough to feel the effort from the self-aligning forces at the road wheel or tire patch.
-
In the diagnosis of a roadability problem, it is important to understand the difference between wander and poor groove feel.
Pinch or Ctrl + scroll to zoom. Double-tap to reset.
Parts & tools for this job For 2007 Mercury Milan 2.3L
- TOOLTie rod end toolSearch: tie rod end puller
- TOOLBall joint separatorSearch: ball joint separator
- FLUIDPower steering fluidSearch: Mercury power steering fluid
Links open Amazon search results in a new tab. As an Amazon Associate I earn from qualifying purchases.