Drive Shaft Inspection (page 2 of 2)
- Make
- Rover
- Model
- 600 Rover 600 Repair Manual - Volumes 1 and 2 - 2nd Edition
- Section
- Repairs
Drive shaftsDrive Shaft Inspection · page 2 of 2
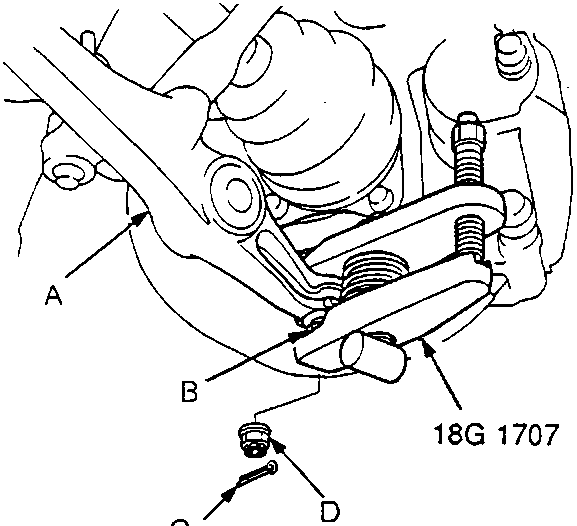
47M0052
- Lower Arm
- Hex Nut
- Cotter Pin
- Castle Nut
- Remove the cotter pin from the lower arm ball joint castle nut. Discard the cotter pin, then remove the nut.
- Install a 12 mm hex nut on the ball joint. Be sure that the hex nut is flush with the ball joint pin end, or the threaded section of the ball joint pin might be damaged by the ball joint remover.
- Use the ball joint remover to separate the ball joint and lower arm.
CAUTION: Be careful not to damage the ball joint boot.
Note: If necessary, apply penetrating type lubricant to loosen the ball joint.
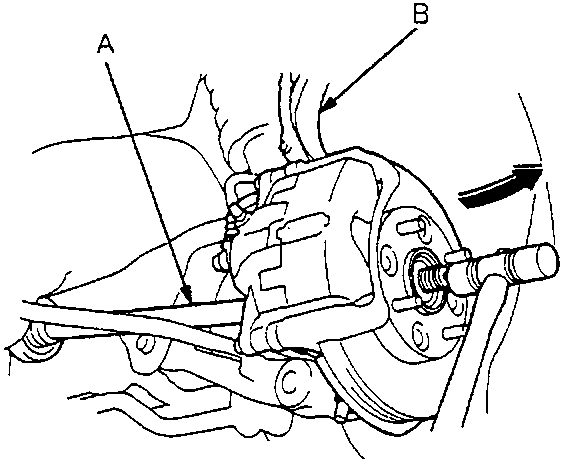
47M0053
- Driveshaft
- Knuckle
- Pull the knuckle outward and remove the driveshaft outboard joint from the front wheel hub using a plastic hammer.
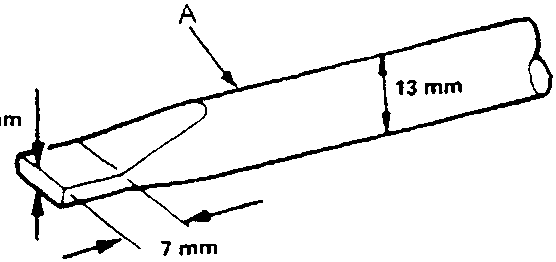
47M0054
- Screwdriver
- Pry the driveshaft assembly with a screwdriver of the dimensions shown to force the set ring at the driveshaft end past the groove.
Parts & tools for this job For Rover 600
- PARTWheel bearingSearch: Rover 600 wheel bearing
- TOOLBearing puller kitSearch: wheel bearing puller kit
- PARTCV boot kitSearch: Rover 600 cv boot kit
Links open Amazon search results in a new tab. As an Amazon Associate I earn from qualifying purchases.