38261E.pdf - Tie Rod - Toyota Land Cruiser J70 Workshop Manual
- Make
- Toyota
- Model
- Land Cruiser Toyota Land Cruiser J70 Workshop Manual
- Section
- Steering › 38261E.pdf - Tie Rod - Toyota Land Cruiser J70 Workshop Manual
38261E.pdf - Tie Rod
SR-64 STEERING — Steering Linkage
Tie Rod
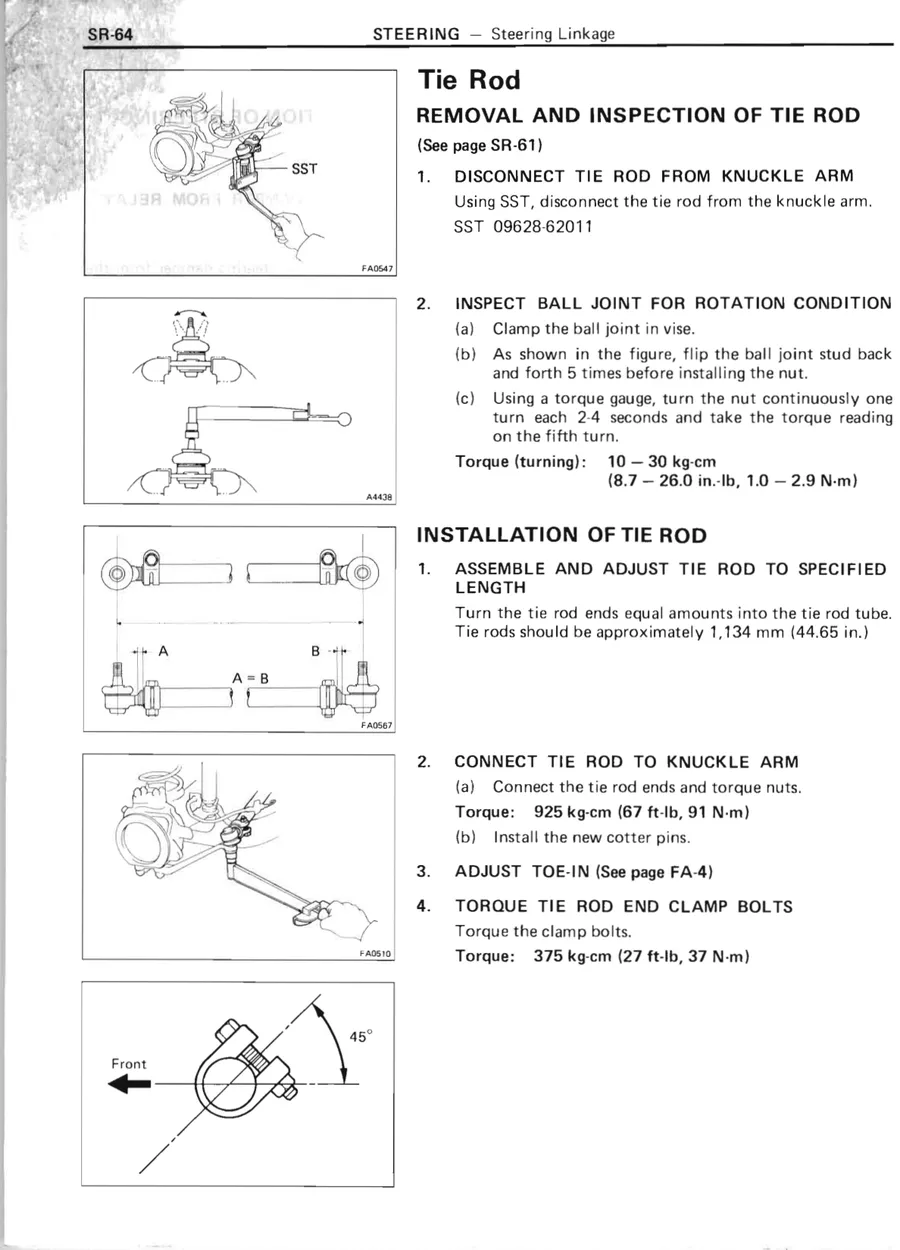
REMOVAL AND INSPECTION OF TIE ROD
(See page SR-61)
1.
DISCONNECT TIE ROD FROM KNUCKLE ARM
Using SST, disconnect the tie rod from the knuckle arm. SST 09628-62011 FA0s47
2.
INSPECT BALL JOINT FOR ROTATION CONDITION
Clamp the ball joint in vise. (a) (b) As shown in the figure, flip the ball joint stud back and forth 5 times before installing the nut. Using a torque gauge, turn the nut continuously one (c) turn each 2-4 seconds and take the torque reading on the fifth turn.
10 — 30 kg-cm
Torque (turning):
7 / PAD
(8.7 — 26.0 in.-Ib, 1.0 — 2.9 N-m)
A446
INSTALLATION OF TIE ROD
ore ==} a (©)
1.
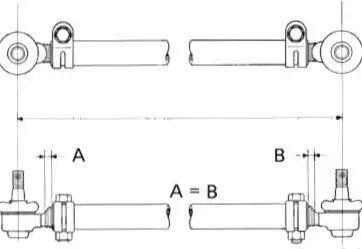
ASSEMBLE AND ADJUST TIE ROD TO SPECIFIED
of ee LENGTH Turn the tie rod ends equal amounts into the tie rod tube. Tie rods should be approximately 1,134 mm (44.65 in.)
F.A0S67
2.
CONNECT TIE ROD TO KNUCKLE ARM
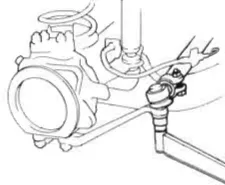
(a) Connect the tie rod ends and torque nuts. Torque: 925 kg-cm (67 ft-lb, 91 N-m) Install the new cotter pins. (b)
3. ADJUST TOE-IN (See page FA-4) \.
4.
TORQUE TIE ROD END CLAMP BOLTS
( Torque the clamp bolts. 80610 Torque: 375 kg-cm (27 ft-lb, 37 N-m)
. 45° Front
Donated by Onur Azeri . cruisercult.com
Parts & tools for this job For Toyota Land Cruiser
- TOOLTie rod end toolSearch: tie rod end puller
- TOOLBall joint separatorSearch: ball joint separator
- FLUIDPower steering fluidSearch: Toyota power steering fluid
As an Amazon Associate we earn from qualifying purchases.