Steering control
- Make
- Fiat
- Model
- 500 Factory Service Manual
- Year
- 2007–2024
- Section
- Steering control and linkage › Steering control
STEERING CONTROL
Introduction
The NGE (Electrical Steering Node) produced by DELPHI has a power-assisted steering device which is designed to lighten the effort required from the driver on the steering wheel especially during steering manoeuvres at low speed without, however, making it too light in normal driving conditions.
Electric power steering offers the following advantages compared with hydraulic power steering:
- The system has fewer components and therefore weighs less and is less complex.
- The installation and/or servicing times are reduced and simpler.
- The electric power steering system only absorbs energy from the engine when servo-assistance is requested, improving the performance of the vehicle and reducing fuel consumption and emissions.
- A reduction in operating noise improves driving comfort.
- Reduction in pollution because the electrical energy used is clean.
- Variation in power assistance depending on vehicle speed.
- Steering return to the centre (active return)
- Steering return oscillation damping
- Selectable power assisted steering (Normal / City / Sport)
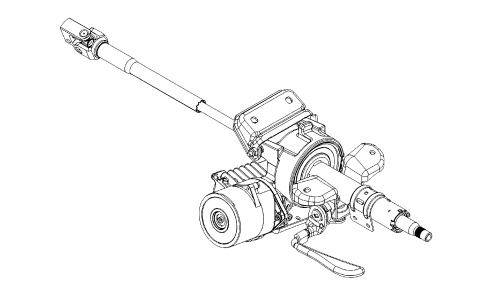
Components
Steering column
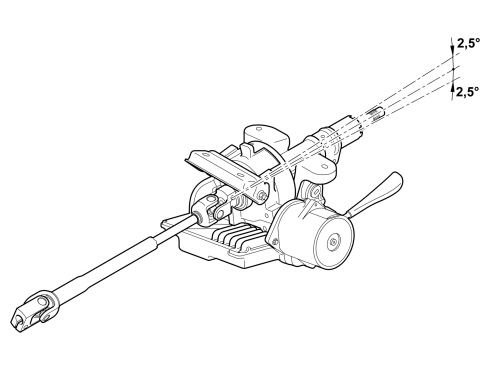
The electrical column is height-adjustable, with a total travel of 5 degrees; the mechanical column has a fixed position
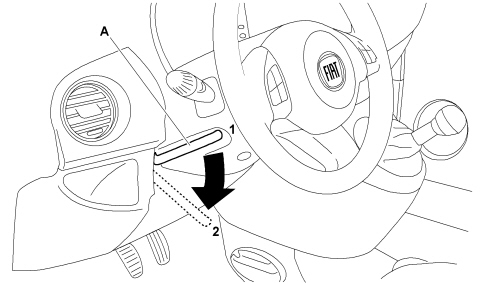
To adjust the position bring lever (1) down to position A after which the steering wheel can be adjusted to the most suitable position and subsequently locked in this position by bringing lever A to position 1.
Steering wheel column composition
The composition of the assembly is illustrated in the diagram below.
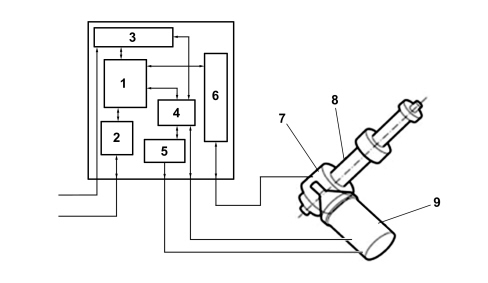
1. Microprocessor
2. CAN interface
3. Supply circuits
4. Engine phase operating circuit (EBMD)
5. Power electronics (FET)
6. Analogue signal interface.
7. Position and torque sensor
8. Servo mechanism
9. Electric motor (with engine position sensor)
Geared motor
The geared motor unit comprises an aluminium casting secured to the vehicle chassis.
Located at the side of the geared motor casting, the servo motor provides the power assistance gear with a torque with a ratio of 22:1 by means of a worm screw.
The geared motor gear, coaxial and in one piece with the steering column, is made of steel, whilst the outer ring gear is made of comoulded plastic. The worm screw and the gear have been designed so that the meshing angles ensure the reversibility of the coupling.
The metal part of the gear is fitted on the output shaft which transmits the total steering forces (in other words the combined torque from the servo motor and the driver).
The input and output shafts are connected to one another by a calibrated torsion bar which allows an angular movement of between +8° and -8° (mechanical ends of travel prevent the torsion from being increased any further).
When there is resistance at the wheels, the input shaft twists the torsion bar; the input shaft and the output shaft are therefore offset at an angle proportional to the torque applied to the steering wheel.
A torque sensor, fitted inside the geared motor, measures the angle displacement between the input shaft and output shaft and supplies an electrical signal to the control unit that is proportional to the displacement.
The geared motor casing also retains the outer part of the torque and position sensor. Lastly, the input shaft support cover is secured to the casing where the steering wheel is fitted, and houses both the ignition switch and the steering wheel interface.
The geared motor casing must not, under any circumstances, be dismantled. It would also NOT be possible to reassemble this complex system like in the factory.
Electric motor
The electric motor is a three-phase self-switching synchronous motor (without blades) with a permanent magnet rotor.
The power distribution and phase control are regulated by the Electric Steering Node management control unit.
The motor rotor is constructed through the application of permanent magnetic material.
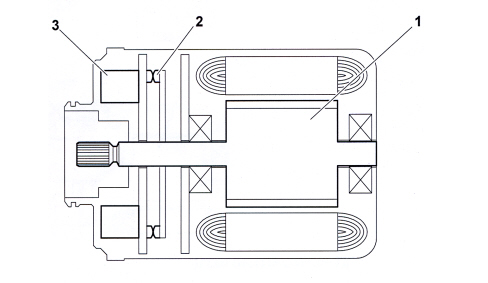
There is a disc with magnets (2) fitted to it, secured to motor rotor (1), whilst there are three Hall-effect semiconductors (3) on the fixed part of the crankshaft, output side. These notify the control unit of the angular position of the crankshaft through 360°. Therefore the position of the rotor (orientation) is measured by the position sensors built into the casing (Hall effect sensors), allowing the control unit to supply the suitable phases.
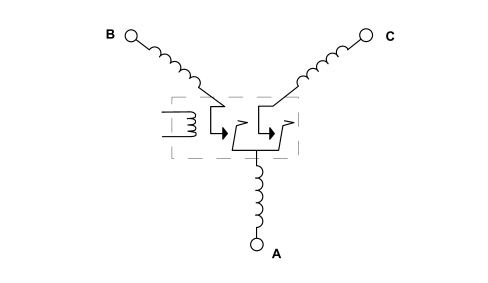
To reduce noise and pulsations at the steering column the motor is fitted with three insulators for the stator and one for the rotor.
The engine current uptake ranges from 1 A to 80 A; the maximum current uptake occurs when evasive measures are taken with high steering wheel rotation speeds.
The motor has been designed to provide the torque required, in other words it has been designed to help the user depending on the effort required on the steering wheel.
The wheels offer different resistance to the steering column depending on whether they are resting on ice or asphalt, for example.
As a result the motor provides the necessary torque.
The Electric Steering Node controls every single (three phase) winding by controlling the current.
As the rotor has permanent magnets it tends to pursue and reach the centre of the magnetic field.
The Electric Steering Node controls the position of the rotor via the signals sent to it by the Hall effect semiconductors.
The control unit uses the exact position of the rotor to send the current (activation) through the coils concerned and therefore ensure that the engine is always delivering torque.
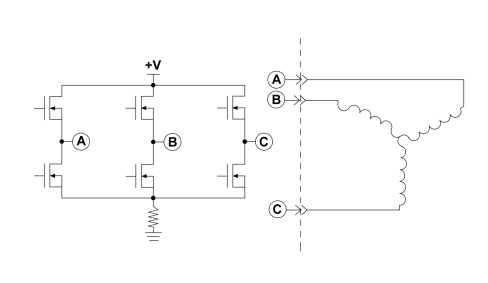
The activation of the individual coil is carried out using the FET bridge illustrated above with a working frequency of 18 KHz using the PWM (Pulse Width Modular) method for each individual coil.
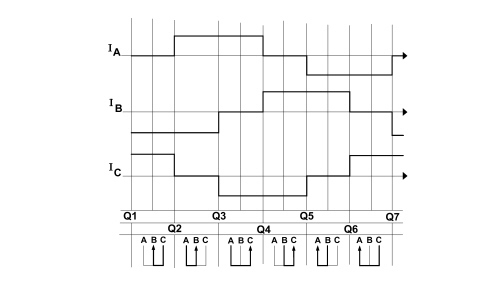
The diagram illustrates how, when the current is supplied to one winding, it is requested in another, whilst in the third winding no current flows through. On switching on, the current flows passing through the coils change.
The synchronized, self-switching motor always operates at the required torque determined by the force exerted by the user on the steering wheel and as the torque demand increases, the value of the current passing through the windings increases proportionally: this value will be around zero when no torque demand is placed on the engine.
The sensor
The sensor that measures torque and position is fitted on a single casing secured to the geared motor casting whilst the input and output shafts are free to rotate, driving the moving measurement parts.
As stated previously, the sensor has two functions: it measures the torque and the position of the output shaft.
When measuring the torque, it can be compared to a potentiometer where the resistive support is secured to the output shaft and the cursor is secured to the input shaft. The twisting moment on the torsion bar between the two shafts determines the value of the torque applied between the steering wheel and the steered wheels.
Through the signal from this potentiometer the control unit is capable of understanding the effort that the driver is exerting on the steering wheel, and the direction of the torque. Through the same principle (potentiometer), it measures the angular position of the output shaft in relation to the centre (wheels straight).
Via the signal, the control unit is capable of understanding by how many degrees the steering wheel has moved in relation to the centre.
On versions with ESP the sensor in question also has the function of a steering angle sensor and is designed to calculate the number of revolutions for the steering wheel and how many degrees per turn.
The information supplied by the torque/position sensor is sent via the C-CAN from the Electric Steering Node for optimum management of the electronic stability control managed by the NFR.
It is prohibited to carry out tests on the sensors using any instruments: any fault diagnosis MUST be carried out using the electric steering control unit.
Lower shaft
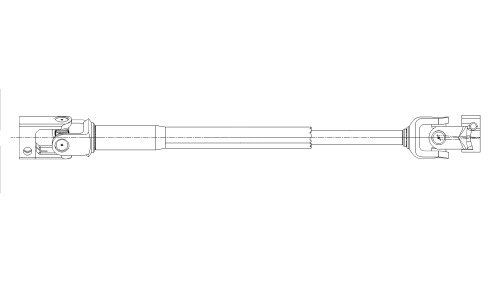
The connection between the steering column output shaft and the steering box pinion is made through a telescopic intermediate shaft that is attached to the pinion by means of a splined fork and a bolt.
Control unit
The electronic unit processes the input signals received from the sensors and operates the electric motor, providing a suitable current to achieve the desired power-assistance torque. It also manages the communication on the CAN and carries out the continuous auto diagnosis of the system to ensure correct operation. The communication on the CAN is managed using the diagnostic equipment.
Vehicle speed, alternator, City/Normal/Sport mode and tuning parameters are read from the CAN line.
The position and torque signals coming from the sensors represent the basic values with which the microprocessor processes the output data in terms of current supplied to the engine.
The steering power assistance control unit is fastened to the electric steering casing itself and interfaces with the wiring by means of two separate connectors: one 10 pin and one 2 pin.
The diagram below shows the control unit pin out.
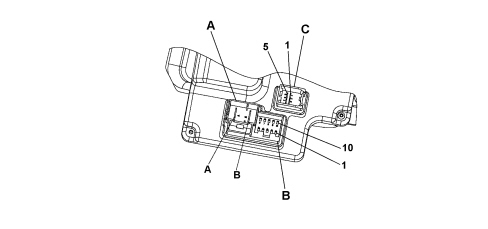
CONTROL UNIT PINOUT
| Connector A | |
|---|---|
| Pin | Function |
| A | Battery + |
| B | Battery - |
| Connector B | |
|---|---|
| Pin | Function |
| 1 | +15 power supply |
| 2 | CAN HI 2 |
| 3 | CAN LO 2 |
| 4 | Not connected |
| 5 | Not connected |
| 6 | Not connected |
| 7 | CAN HI |
| 8 | CAN LO |
| 9 | Not connected |
| 10 | Not connected |
| Connector C | |
|---|---|
| Pin | Function |
| 1 | P 3 (ESP only) |
| 2 | P 1 |
| 3 | Sensor reference power supply |
| 4 | T2 |
| 5 | Not connected |
| 6 | P2 |
| 7 | Earth |
| 8 | T1 |
BASIC OPERATION
Depending on the driver''s requirements (torque at the steering wheel) and the speed of the vehicle, the electric steering node management control unit (NGE) controls the electric servo motor that assists the steering column to rotate.
The motor applies a torque to the actual steering column by means of a worm screw mechanism, thereby saving the driver steering effort.
Variable servo assistance depending on the speed of the vehicle
As the speed of the vehicle increases the user proportionally increases the effort applied to the steering wheel because the resistant force at the wheels decreases as the vehicle speed increases.
As a result, making use of the vehicle speed signal, the NGE implements a lesser degree of steering assistance.
Active return
The return stage refers to the realignment function naturally imposed by the vehicle front end geometry when the steering is released after a steering manoeuvre.
This function is designed to make the realignment quicker causing the servo motor to intervene to help the normal geometric effect.
The active return correction varies depending on the speed of the vehicle:
- It is greatest at low speeds
- It is lowest at high speeds.
The servo motor carries out the active return of the steering wheel according to the steering angle in relation to the centre. The greater the steering angle, the greater the effort of the motor to realign the wheels.
Steering return oscillation damping
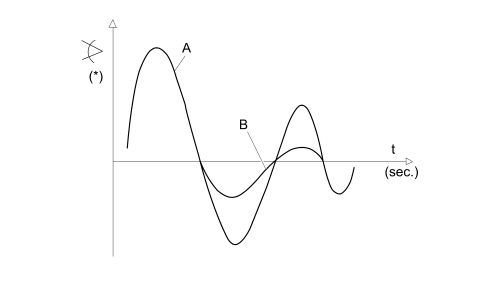
After the steering wheel is released, following a steering manoeuvre, the vehicle chassis produces oscillations (A) which, if they persist for a while, can become tiresome.
The servo motor reduces the extent of the oscillations (B) during the return to the straight line driving route and intervenes more at high speeds.
Selectable power assisted steering
The user can choose between two driving modes using the button in the control panel:
- Normal for normal power assistance at medium and high speeds,
- City for easier driving whilst parking and at low speeds thanks to greater assistance.
Description of the signals
Normal / city / sport driving mode selection signal
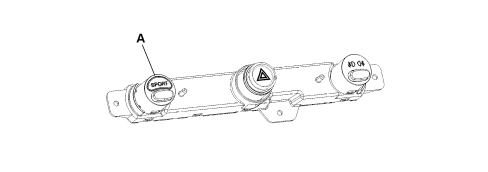
A. Sport button
The Normal / City function varies the power assistance torque depending on the speed of the vehicle.
It is possible to switch from a basic Normal configuration to a City or a Sport one using the button with one fixed position in the control panel.
The Electric Steering Node system receives the Normal / City / Sport signal from the C-CAN and implements the requested strategy.
The Body Computer Node is designed to receive an analogue signal that is modulated when the button is released to turn on the relevant signal and when the torque applied by the driver is more than 1 Nm.
During the ignition STOP/MAR cycle, the Body Computer Node maintains the status requested previously by the user.
The steering is still assisted and decreases as the speed increases.
C-can line
The control unit is capable of receiving/sending information on the CAN, with this network interface operational from when the key is turned on until it is turned off.
Signals received / sent via the c-can
The signals received by the Electric Steering Node control unit on the CAN are:
- Vehicle speed
- Failure light status
- Engine running signal (D+)
- Diagnosis
- Vehicle speed signal error
- Normal/City/Sport mode
- Type of tuning (calibration)
The signals sent by the Electric Steering Node control unit on the CAN are:
- System status (failure)
- Servo-steering signal activated bulb failure status
- Diagnosis
- Steering wheel absolute position (only for Electric Steering Node version for applications with ESP)
Functional diagram
The following image shows the functional layout of the operation of the electric steering.
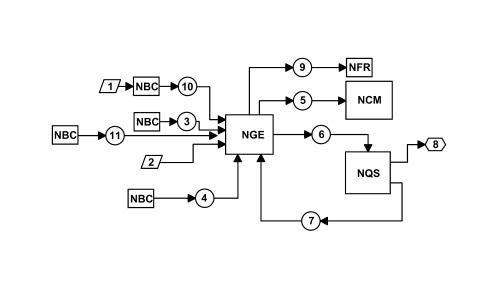
1. City/Sport driving selector
2. Ignition key
3. Alternator voltage
4. Vehicle speed
5. Steering load
6. Warning light fault status sending
7. Warning light fault status return
8. Fault and/or City/ Sport warning light on
9. Steering angle position signal (only with ESP)
10. City / Normal / Sport signal from NBC
11. Tuning type signal (calibration) from NBC
Operational behaviour
The functional behaviour of the system is illustrated in the table below.
| INPUT | OUTPUT |
|---|---|
| Vehicle speed reading (4) (via CAN) | Regulates the power steering depending on the speed of the vehicle and the recommended torque for the steering wheel. |
| Alternator D+ reading (3) (via CAN) | The control module is able to know from this reading whether the engine has been started. |
| System error | Failure warning light on via CAN. |
| Normal/City/Sport selection (included in the system) | Depending on the request made by the driver using the button, the system activates the corresponding strategy (hard/soft). |
| System electrical load (system reading) | The system transmits this information to the engine control module via the CAN and the module, in turn, implements the appropriate strategy for regulating the engine idle speed. The Electric Steering Node control panel is able to identify the changes in the timing of the current taken up by the node during operation. The control panel recognises if the positive and negative thresholds are exceeded and re-sends this information over the CAN. |
Parts & tools for this job For 2007 Fiat 500
- TOOLTie rod end toolSearch: tie rod end puller
- TOOLBall joint separatorSearch: ball joint separator
- FLUIDPower steering fluidSearch: Fiat power steering fluid
Links open Amazon search results in a new tab. As an Amazon Associate I earn from qualifying purchases.